Smart Pouring: Watering Plants from Phone Videos
How far can 48 phone videos of my own hands take a robot? SmolVLA learns to water plants in simulation: 96% grasp, 50% full task.
Research, coursework and personal builds across machine learning and robotics, from vision-language-action models to state estimation on real hardware.
How far can 48 phone videos of my own hands take a robot? SmolVLA learns to water plants in simulation: 96% grasp, 50% full task.
 ViCoS Lab2026
Research project
Language-conditioned queries score the native X-VLA image-token grid to expose which regions matter for the current manipulation step.
ViCoS Lab2026
Thesis work
Recover expert perceptual structure from X-VLA representations such as DINOv2-like tokens or CeDiRNet-aligned maps to support action guidance and representation alignment.
Computer Vision Lab2026
First author · Accepted at IJCB
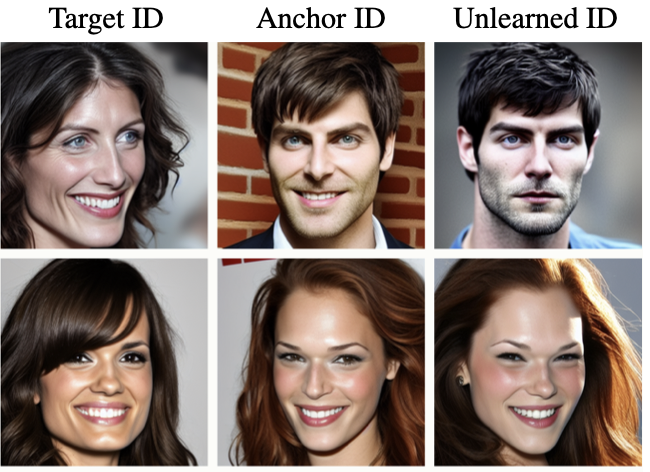
PIU protects a chosen identity in ID-conditioned diffusion models by re-teaching what its identity conditioning means, so the model stops generating that person while image quality stays intact.
 Saveware2025
Case study: trailer loading with multi-SKU shipments.
Two-stream encode–attend–fuse architecture that ingests global operation features and per-item (sub-operation) features, and predicts both a baseline duration and its uncertainty σ with a heteroskedastic Gaussian head.
 Tec de Monterrey2023
Implementation of Deep Deterministic Policy Gradient (DDPG) with Hindsight Experience Replay (HER) for robotic manipulation task using xArm6.
Tec de Monterrey2024
Tec de Monterrey2024
Gazebo simulation of a differential drive robot, fusing wheel-encoder odometry with LIDAR landmark (corner) detections using an Extended Kalman Filter (EKF).
The EKF corrects pose estimation with measurement updates from detected corners for continuous, drift-reduced localisation.
Tec de Monterrey2024
Implementation of a control strategy mapping image-point errors to differential-drive commands, following Siradjuddin et al.
 Rice University2024
Implementation of Samsung’s SceneGrasp model for multi‑object 3D reconstruction, 6DoF pose, and grasp prediction in an UR5 robot and external RGB‑D camera setup .
Design of the ROS1 system considering robot kinematics and multi-frame of reference translations.
Tec de Monterrey2023
Implementation of a self-trained Deep Deterministic Policy Gradient (DDPG) model for xARM6 tilt-stable navigation and manipulation tasks using ROS.
Tec de Monterrey2023
Implementation of visual servoing techniques for the xArm6 robotic arm, enabling precise control based on external camera's visual feedback.
Tec de Monterrey2023
Development of an self-driving vehicle prototype using ROS1, YOLOv5, and Nvidia Jetson Nano. Autonomous navigation system prototype using CV-based traffic signals detection and line following with adaptive linear control.
Tec de Monterrey2023
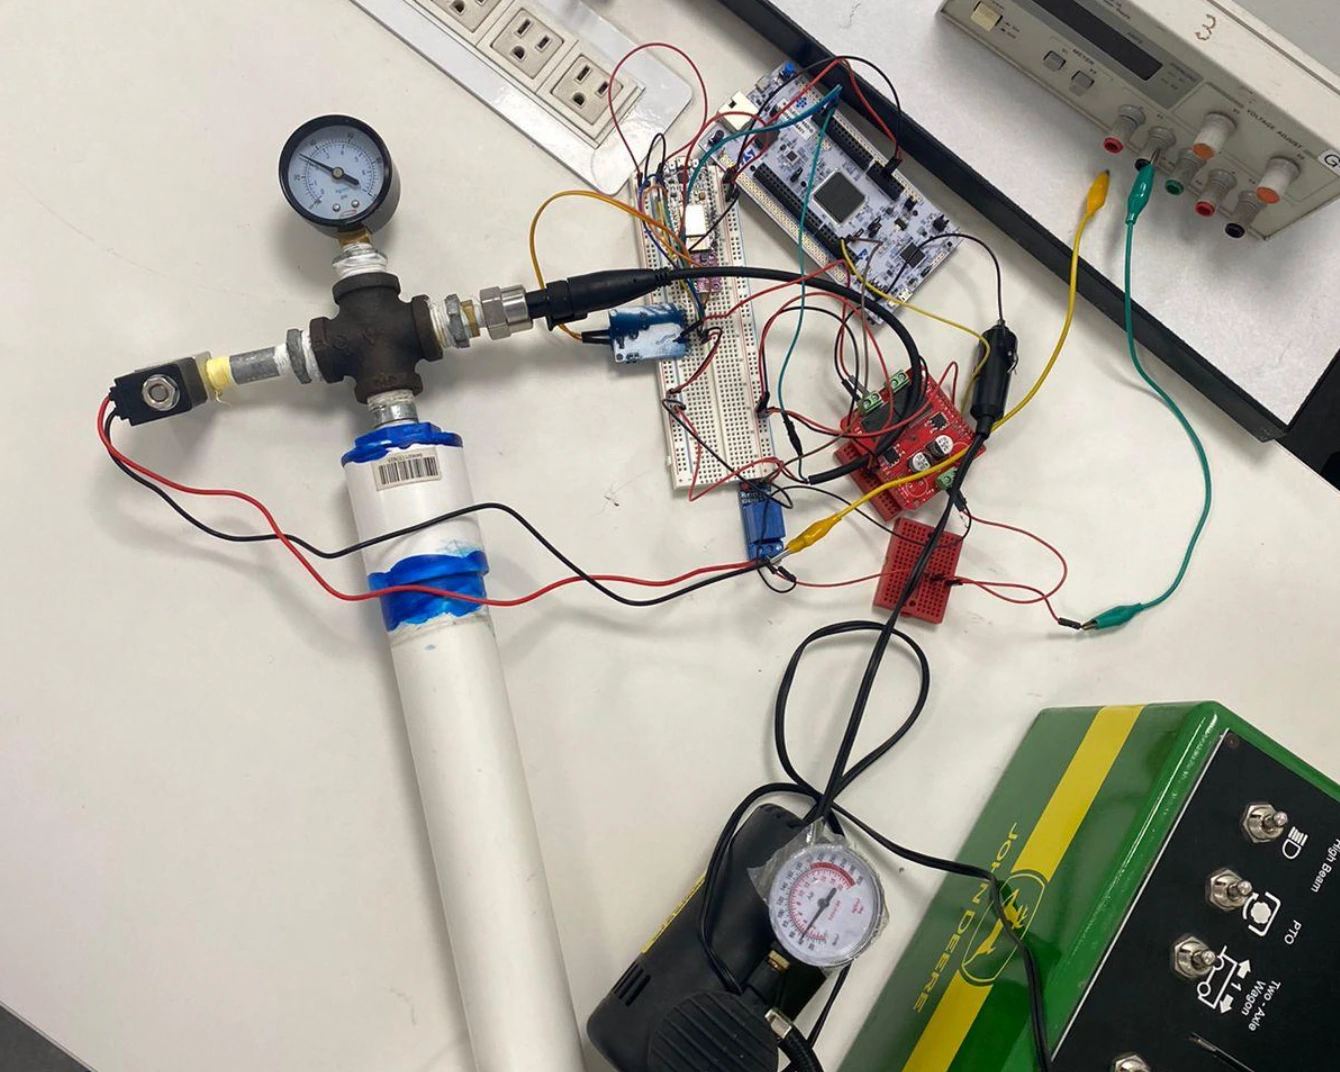
A prototype for an intelligent air pressure control system for tires in agricultural equipment using linear (PID) control strategies.
Developed using an ARM cortex processor in a dual core STM32 board. Utilized CAN, and serial protocols for sensor communication and a NodeMCU device for internet connectivity and online data visualization.