J.E. Hernandez Spain · Open to relocation
Research index · Vol. 2026Robotics × Machine learning

J. Edgar Hernandez.

Generative and robot learning: vision-language-action models, multimodal reasoning and representation alignment.

I take learning from paper to real robot: VLAs, LeRobot, sim and hardware. I keep going until it works.

Education
MSc Artificial Intelligence2026Erasmus Mundus · EMAI ↗ BSc Robotics Engineering2024Tec de Monterrey
Thesis
Visual Thought Tokens for Vision-Language-Action Models2026
Published
PIU: Proximity-guided Identity Unlearning2026IJCB · First author
Languages
English · Spanish · Italian A2
01

Robot learning

VLA models, imitation and reinforcement learning for manipulation.

02

Representations

Alignment, distillation and token-level grounding in large models.

03

Generative models

Diffusion and score-based models, identity unlearning.

04

Robotics systems

ROS, motion planning and visual servoing on real hardware.

Stack
  • PyTorch
  • Hugging Face
  • LeRobot
  • ROS
  • Docker
  • W&B
  • AWS
  • Google Cloud

Selected work

All research →
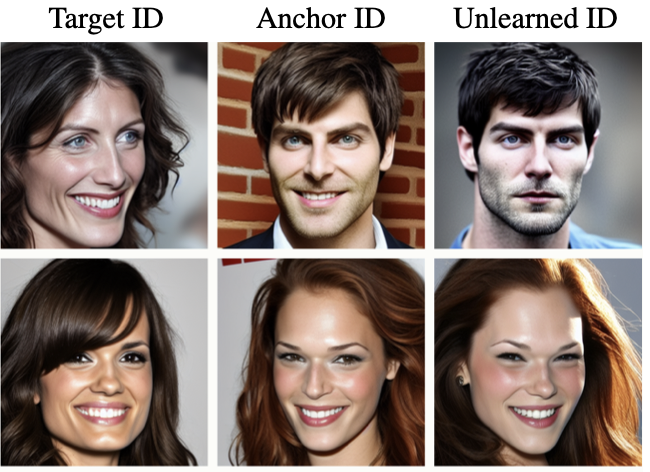
PIU identity unlearning examples: target, anchor and unlearned identities
Fig. 01

IJCB 2026 · First author

PIU: Proximity-guided Identity Unlearning in ID-Conditioned Diffusion Models

Making a face generator forget one person by re-teaching what their identity means, while image quality stays intact.

Computer Vision Laboratory, University of Ljubljana
Fig. 04

Humanoid challenge · 2026

Smart Pouring: Teaching a Robot to Water Plants from Phone Videos

How far can 48 phone videos of my own hands take a robot? SmolVLA learns to water plants in simulation: 96% grasp, 50% full task.

SmolVLA · LeRobot · LIBERO

Trajectory

Full CV ↓
  1. 2026 — Present

    AI Engineer, R&D (Part-Time)

    Anzures

    Generation pipeline for a diffusion-based virtual try-on product: quantization, LoRA fine-tuning, prompt engineering and systematic quality evaluation.

  2. 2024 — 2026 Erasmus Mundus Joint Master in AI

    MSc Artificial Intelligence

    Erasmus Mundus · UPF Barcelona → Sapienza Rome → Univ. of Ljubljana

    Specialization in data science at the University of Ljubljana; thesis at ViCoS on perceptual guidance for vision-language-action models.

  3. 2022 — 2025 Saveware

    Machine Learning Engineer (Part-Time)

    Saveware · Startup project at Lavatap, Monterrey

    Built the AI for a trailer-loading time prediction product: an attention-based model with uncertainty estimation, trained on data collected in-house and outperforming XGBoost, linear regression and SVR baselines.

  4. 2024 — 2024 Rice University

    Visiting Researcher

    Kavraki Lab · Rice University

    ROS system integrating motion planning with SceneGrasp for multi-object 3D reconstruction and grasp pose estimation from RGB-D; pick-and-place validated in simulation and on hardware.

  5. 2022 — 2023 Steelcase

    Business Automation Intern

    Steelcase

    Automation for internal business processes with Python, UiPath RPA, Power Automate and Excel VBA, in an Agile team.

  6. 2019 — 2024 Tecnológico de Monterrey

    BSc Robotics & Digital Systems

    Tecnológico de Monterrey

    Digital and embedded systems, intelligent and robotic systems, automation and control.